openDog V3
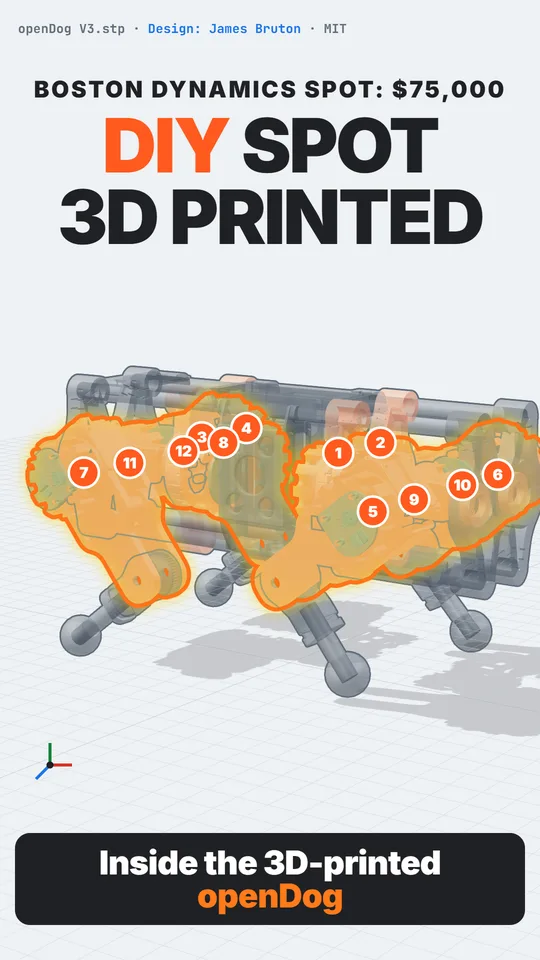
A big 3D-printed robot dog with 12 brushless motors.
- Cost
- not statedthe repo gives no total; it's a high-cost build
- Difficulty
- 5/5
- Build time
- Weeks
- Skills
- Lots of printing · Brushless motors + ODrive · Electronics
Made by James Bruton · License MIT
The files are hosted by the maker. We never re-upload them.
What it is
A large, Spot-style four-legged robot from YouTuber James Bruton. Twelve big brushless motors with printed gearboxes power the legs, all printed in PLA, with silicone feet cast in printed molds.
How it works
- 12 brushless motors, three per leg (hip, shoulder and knee), driven by 6 ODrive boards.
- All the motors sit up in the body. The knees are driven by belts, which keeps the legs light.
- Each motor has a printed 10:1 cycloidal gearbox, with 384 small bearings across the whole dog.
- Brain: a Teensy 4.1. There are two emergency-stop buttons, just in case.
What you need
- 12× 9225 brushless motors and 6 ODrives
- Belts, bearings, carbon parts (BOM in the repo)
- A Teensy 4.1 and a big LiPo battery
- Silicone for the feet
Parts we use
- Controller boardsTeensy 4.1Amazon ★
- Sensors & camerasMPU-6050 IMU moduleAmazon ★
- Power6S LiPo battery (22.2 V)Amazon ★
- Motors/driversODrive-compatible BLDC driver (ODESC V4.2)Amazon ★
- 3D printingPLA filament 1.75 mm (Bambu Lab PLA Basic)Amazon ★
- 3D printingPLA filament 1.75 mm (Polymaker PolyLite PLA Pro)Amazon ★
★ = affiliate link. If you buy through it, we may earn a small commission at no extra cost to you. As an Amazon Associate we earn from qualifying purchases. Check the maker's bill of materials for exact quantities; prices change.
Is it for me?
Advanced and expensive. Watch the build series first; it's one of the best ways to learn how big legged robots work.
Official links
Summary written by us in plain words. Not affiliated with or endorsed by James Bruton. Prices and links last checked Nov 3, 2026. Are you the maker and want something changed? Email us.