Berkeley Humanoid Lite
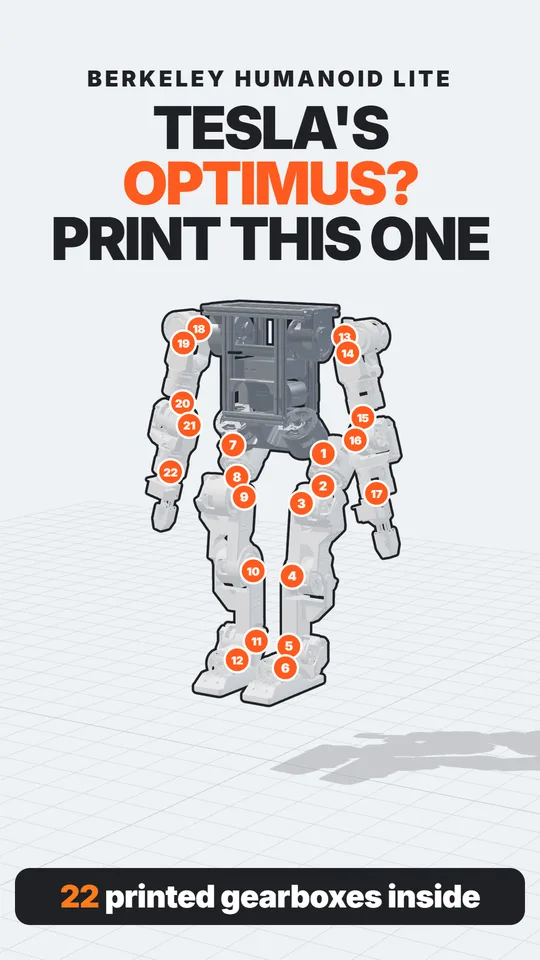
A walking humanoid with 22 3D-printed gearboxes.
- Cost
- under US$5,000about US$4,312 in parts, per the paper
- Difficulty
- 5/5
- Build time
- Weeks to months
- Skills
- Lots of printing · Brushless motors · Robot learning
Made by Hybrid Robotics lab, UC Berkeley · License CC BY-SA 4.0 (assets) · MIT (code)
The files are hosted by the maker. We never re-upload them.
What it is
A mid-size humanoid from a UC Berkeley lab that learns to walk with reinforcement learning. Every joint is a motor with a 3D-printed cycloidal gearbox, and the lab ran one for 60 hours straight to prove the plastic holds up.
How it works
- 22 joints: 6 in each leg and 5 in each arm, each one a self-contained actuator.
- The motors are drone motors, far too fast for a knee, so each gets a printed cycloidal gearbox to slow it down and add force.
- A cycloidal disc wobbles inside a ring of pins, so many bumps share the load. That's how printed plastic survives.
- It walks with a policy trained in simulation (Isaac Lab), and a person can steer the arms for tasks like a Rubik's Cube.
What you need
- 22 brushless motors and their controllers
- A lot of PLA printing
- Power, compute and the release-page files
- Patience
Parts we use
- Motors/driversUSB to CAN adapterWaveshare ★
- 3D printingPLA filament 1.75 mm (Bambu Lab PLA Basic)Amazon ★
- 3D printingPLA filament 1.75 mm (Polymaker PolyLite PLA Pro)Amazon ★
★ = affiliate link. If you buy through it, we may earn a small commission at no extra cost to you. As an Amazon Associate we earn from qualifying purchases. Check the maker's bill of materials for exact quantities; prices change.
Is it for me?
Advanced. Read it to learn how printed gearboxes work; build it if you already have a few robots behind you.
Official links
Summary written by us in plain words. Not affiliated with or endorsed by Hybrid Robotics lab, UC Berkeley. Prices and links last checked Nov 3, 2026. Are you the maker and want something changed? Email us.